Automation is changing the way industries operate. Robots are no longer limited to isolated manufacturing tasks or repetitive activities performed behind safety barriers. Autonomous machines are increasingly being developed to operate in environments where people are also present, including warehouses, hospitals, laboratories, agricultural fields, logistics facilities, construction sites and service industries. These machines can move independently, recognise objects, interpret environmental information, respond to instructions and perform tasks that previously required continuous human supervision. As a result, the modern workplace is gradually evolving into a shared environment where humans and autonomous systems must coordinate their actions.
This transformation introduces an important educational challenge. Preparing students for an automated workplace is not simply a matter of teaching them how to operate robots or understand programming languages. Future professionals will also need to know how to communicate with autonomous systems, interpret machine behaviour, coordinate tasks, recognise operational risks and intervene when automated decisions produce unexpected outcomes. They must understand not only what machines can do, but also how human judgement and machine capabilities can work together.
The difference between knowing how to use a robot and knowing how to coordinate with one represents a significant distinction in technical education. A student may understand robotics concepts, complete a programming course or operate a robotic arm in a laboratory without developing the practical judgement required to work safely alongside an autonomous machine. This creates what can be described as the Human-Robot Coordination Gap: the distance between the technical knowledge students acquire about robotics and their ability to collaborate effectively with autonomous machines in real working environments.
For an education ecosystem such as EasyShiksha, this emerging gap creates an opportunity to connect technical courses, interactive assessments, simulation-based learning, practical projects, internships, university programmes and career guidance. The objective would be to help students develop the technical understanding and coordination skills needed for workplaces in which humans and intelligent machines increasingly share responsibility.
Understanding the Human-Robot Coordination Gap
The Human-Robot Coordination Gap refers to the difference between the skills required to work effectively with autonomous machines and the capabilities developed through conventional educational programmes. Traditional robotics education often concentrates on machine construction, programming, sensors, control systems, mechanical components and automation principles. These subjects are essential, but they do not necessarily prepare students for the complexities of human-robot collaboration.
Working alongside an autonomous machine requires a broader understanding of how tasks, information, responsibility and physical movement are shared. A warehouse employee working with an autonomous mobile robot must understand its movement patterns, operating boundaries and communication signals. A healthcare professional interacting with a robotic assistance system must recognise which activities can be delegated and which require direct human judgement. An engineer supervising an automated production line must understand how to respond when a machine behaves differently from its expected operating pattern.
These situations involve technical knowledge, but they also require situational awareness, communication, decision-making, risk assessment and an understanding of human and machine limitations. A student who understands the internal components of a robot may still be unprepared to recognise when the robot's movement creates a safety concern or when an automated system needs human intervention.
The coordination gap therefore exists between machine knowledge and collaborative capability. Closing it requires educational programmes to move beyond teaching students how autonomous machines function and begin preparing them to work with those machines as part of a shared operational system.
From Robot Operation to Human-Robot Collaboration
Robotics education has traditionally placed considerable emphasis on operating machines. Students learn how to write control instructions, configure robotic components, connect sensors and execute predefined tasks. These activities provide important technical foundations, but collaboration requires a different level of understanding.
In a collaborative environment, the human and the machine may perform separate but connected activities. A robot might transport materials while a human technician performs quality inspection. An autonomous agricultural machine may identify areas requiring treatment while a farm worker supervises the operation. In a hospital, an automated delivery system may transport supplies while medical staff remain responsible for patient-related decisions.
The human and the robot are not necessarily performing identical tasks. Their roles are distributed according to their respective capabilities. Machines may provide consistency, speed and the ability to process large volumes of sensor information, while humans contribute contextual understanding, ethical judgement, adaptability and responsibility.
Students therefore need to understand task allocation and coordination. They must learn how to determine which tasks are appropriate for automation, where human supervision remains necessary and how responsibilities should be transferred when operating conditions change. This is a more complex educational objective than simply teaching students to activate or program a robot.
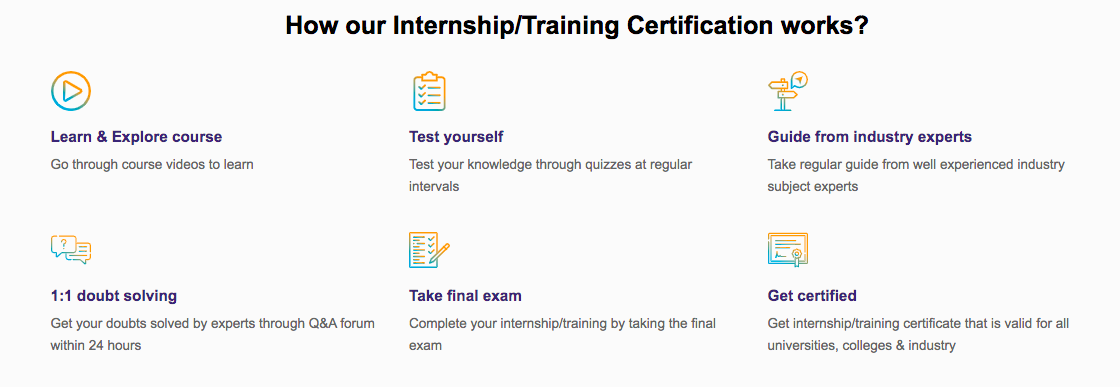
How EasyShiksha Internship/Training Program Works
Why Technical Education Needs a New Competency Framework
The growing presence of autonomous machines requires technical education to reconsider what it means to prepare a student for employment. A traditional robotics curriculum may successfully teach mechanical design, electronics, programming and automation. However, a graduate entering a collaborative workplace may also need to interpret robot status information, understand safety procedures, coordinate movement, communicate operational requirements and evaluate system reliability.
These capabilities cannot be developed through theoretical instruction alone. Students need opportunities to experience situations in which human and machine activities interact. They must understand how decisions made by one participant affect the actions of another.
A new competency framework could combine robotics fundamentals with human-machine interaction, collaborative task planning, workplace communication, safety engineering, sensor interpretation and operational decision-making. Such a framework would also include the ability to recognise uncertainty and respond when autonomous systems encounter situations outside their expected operating conditions.
The purpose is not to replace traditional engineering subjects. Mechanical engineering, computer science, electronics, artificial intelligence and control systems remain essential. Instead, the objective is to connect these disciplines with the practical realities of collaborative work.
Understanding Shared Autonomy
One of the most important concepts in human-robot coordination is shared autonomy. Shared autonomy describes situations in which humans and autonomous systems contribute to controlling or completing a task. The level of human involvement can vary depending on the activity, operating environment and capabilities of the machine.
In some situations, the human provides high-level instructions while the robot determines how to execute them. In others, the robot performs most of the operation but requests human input when it encounters uncertainty. There may also be situations in which a human continuously supervises the machine and can intervene whenever necessary.
Students need to understand that autonomy is not necessarily an all-or-nothing condition. A machine can operate independently during one stage of a task while requiring human guidance during another. The degree of autonomy may change according to risk, environmental complexity and system confidence.
Educational simulations could help learners explore these different arrangements. A student might supervise a simulated robot that transports objects through a warehouse. Under normal conditions, the robot follows its route independently. When an unexpected obstacle appears, the system may request assistance or calculate an alternative path. The student must decide whether to allow autonomous recovery, provide a new instruction or temporarily take control.
Such experiences can help students understand that effective collaboration depends on knowing when to delegate, when to supervise and when to intervene.
The Importance of Predicting Robot Behaviour
Successful coordination requires people to develop an accurate understanding of what a machine is likely to do next. This ability is closely related to situation awareness and the development of appropriate expectations about system behaviour.
A person working near an autonomous robot must understand its movement patterns, operating boundaries, intended destination and possible responses to environmental changes. If the human cannot predict the machine's next action, coordination becomes difficult and potentially unsafe.
For example, an autonomous mobile robot moving through a warehouse may temporarily change direction to avoid an obstacle. A worker who understands the robot's navigation behaviour can anticipate the movement and maintain a safe distance. Someone unfamiliar with the system may misinterpret the change and move into its path.
Educational programmes can address this challenge by exposing students to robot behaviour under different operating conditions. Instead of showing only successful demonstrations, simulations should include changes in obstacles, visibility, sensor readings, route availability and task priorities.
Students can then learn to interpret machine behaviour rather than treating the robot as a device that always follows a predictable sequence. This develops a more realistic understanding of autonomous systems and the uncertainty involved in their operation.
Developing Trust Without Blind Dependence
Trust is an important part of human-robot collaboration. People must have sufficient confidence in autonomous systems to work with them, but excessive trust can create serious problems. If a student assumes that a robot is always correct, they may fail to recognise errors, limitations or unsafe behaviour. If they distrust every machine decision, they may constantly interrupt the system and prevent it from operating effectively.
The objective should be calibrated trust. Students should understand when a machine is reliable, when its output requires verification and when human judgement must take priority.
This requires more than teaching students that robots can make mistakes. They need to understand why errors occur. Sensor limitations, environmental changes, incomplete information, software defects and unexpected physical interactions can all affect autonomous performance.
An educational exercise could present students with a robot that identifies objects in a simulated industrial environment. Under normal lighting, the system performs accurately. When lighting conditions change or an object becomes partially obstructed, its recognition performance deteriorates. Students must examine the available information and determine whether the machine's decision can be trusted.
Such activities can develop critical judgement and help future professionals avoid both blind acceptance and unnecessary rejection of automated systems.
Human-Robot Communication Is More Than Giving Commands
Communication between humans and robots is often understood as issuing instructions through a control panel, voice interface or software application. However, effective collaboration requires information to move in both directions.
Humans need to communicate task requirements, constraints, priorities and changes in operating conditions. Robots must communicate their status, intended actions, limitations, warnings and requests for assistance. If this information is unclear, coordination can fail even when the underlying technology functions correctly.
Students therefore need to understand the principles of human-machine interfaces and interaction design. They should learn how information can be presented through visual signals, displays, sound, movement patterns and structured instructions. They should also understand why interfaces must be designed around the needs and capabilities of the people using them.
For example, an industrial robot may communicate that it is entering a restricted operating area. The warning must be noticeable, understandable and delivered at an appropriate time. A complicated interface that requires workers to interpret technical messages under pressure can create unnecessary operational risks.
By incorporating interface design and communication exercises into technical education, students can understand that the quality of human-robot coordination depends not only on machine intelligence but also on how effectively information is exchanged.
The Role of Spatial Awareness and Movement Coordination
When humans and robots share physical space, coordination becomes a spatial problem as well as a technical one. Both participants must operate without creating unnecessary interference or danger.
Collaborative robots, often called cobots, are designed for applications in which people and robotic systems work in close proximity. However, safe collaboration still depends on appropriate system design, risk assessment, operating procedures and the correct use of protective measures. The presence of a collaborative robot does not automatically make every interaction safe.
Students need to understand concepts such as operating zones, restricted areas, movement trajectories, stopping distances and collision risks. They should also recognise that human movement is less predictable than the movement of a machine following a programmed route.
Simulation environments can provide useful opportunities to explore these interactions. A student could coordinate a virtual robot and a human worker performing different stages of an assembly task. The learner would need to identify possible movement conflicts and adjust the task sequence to reduce interference.
This type of learning connects robotics with mechanical engineering, industrial engineering, workplace safety and human factors. It also demonstrates why coordination skills cannot be developed through programming instruction alone.
Teaching Students to Manage Unexpected Situations
Autonomous systems are designed to operate under defined assumptions, but real environments rarely remain perfectly predictable. Objects may move unexpectedly, sensors may produce incomplete information, communication networks may become unavailable and tasks may change while a robot is operating.
The ability to respond to these situations is an important part of human-robot coordination. Students must learn how to recognise abnormal behaviour, assess the seriousness of a problem and decide whether the machine should continue, pause, request assistance or enter a safe state.
This requires the development of operational judgement. A student should not simply memorise a procedure for restarting a robot. They should understand why the procedure exists, what conditions make it appropriate and when a different response is required.
Scenario-based learning can help develop this capability. Students might encounter a simulated delivery robot that loses access to its preferred route, an automated inspection system that produces inconsistent results or a robotic arm that detects an unexpected object in its workspace. They would then analyse the situation and determine the appropriate response.
Such activities can introduce students to fault recognition, recovery planning, escalation procedures and the importance of maintaining human oversight.
Why Simulation Should Become a Core Part of Robotics Education
Physical robotics laboratories are valuable, but they can be expensive to establish and maintain. They require hardware, sensors, safety equipment, technical supervision and suitable physical space. Students may also have limited opportunities to experiment because equipment must be shared and physical testing can involve operational risks.
Virtual simulation can complement these laboratories by allowing students to explore a wider range of coordination scenarios. A digital environment can reproduce a warehouse, factory, hospital corridor or agricultural setting without requiring a complete physical installation.
Students can test different robot movements, modify task priorities, introduce obstacles and observe how changes affect human-machine coordination. They can also repeat the same scenario under different conditions and compare the results.
For EasyShiksha, simulation-based learning could become an important extension of online technical courses. Students could first learn robotics concepts through structured lessons, then explore simulated coordination tasks, complete assessments and develop projects that demonstrate their understanding.
Simulation should not be presented as a complete substitute for physical experience. Real robots introduce mechanical behaviour, sensor imperfections, latency and environmental factors that virtual models may not reproduce perfectly. A strong educational pathway would therefore combine virtual experimentation with supervised practical activities wherever possible.
Artificial Intelligence and the Changing Nature of Collaboration
Artificial intelligence is expanding the capabilities of autonomous machines. Modern systems can use computer vision, machine learning, natural language processing and sensor fusion to interpret their environments and respond to changing conditions.
This development makes human-robot coordination more complex. Earlier automated systems often performed clearly defined tasks according to fixed instructions. AI-enabled machines may interpret information, classify objects, generate predictions and select actions based on changing inputs.
Students must understand the difference between a programmed response and a system that uses learned models or probabilistic predictions. They should know that AI outputs can involve uncertainty and that a system's confidence does not necessarily guarantee correctness.
For example, a robot using computer vision may identify an object as a particular tool or component. If the object is partially hidden or visually similar to another item, the prediction may be incorrect. A human collaborator must understand when verification is necessary.
Educational programmes can introduce students to AI-assisted robotics through practical examples involving object recognition, navigation, task planning and human instruction. This creates a connection between artificial intelligence education and the real operational challenges of autonomous systems.
Human-robot coordination is not determined by machine performance alone. It is also influenced by human attention, memory, physical capabilities, workload, experience and decision-making.
Human factors engineering studies how systems can be designed to work effectively with the people who use them. In robotics education, this perspective is essential because a technically advanced machine may still be difficult to use if its interface is confusing, its warnings are poorly designed or its behaviour does not match human expectations.
Students should learn how fatigue, distraction, time pressure and information overload can affect coordination. A worker supervising several autonomous systems may have to monitor multiple status displays while also responding to changing workplace conditions. If the system provides too many alerts or fails to prioritise important information, the worker may miss a critical warning.
Educational exercises can demonstrate how interface design, task distribution and alert management influence human performance. This would help students understand that successful automation depends on designing the entire human-machine system rather than optimising the robot in isolation.
Interdisciplinary Learning: Connecting Robotics With Psychology and Design
Human-robot coordination cannot be fully understood through mechanical engineering or computer science alone. It brings together several disciplines, including robotics, artificial intelligence, psychology, ergonomics, industrial design, communication, safety engineering and ethics.
Psychology helps explain how people perceive machine behaviour, develop trust and respond to uncertainty. Industrial design influences how machines communicate through their physical form and interfaces. Ergonomics examines how people interact with equipment and workspaces. Safety engineering provides methods for identifying hazards and reducing operational risks.
This interdisciplinary nature creates an opportunity for educational programmes to connect subjects that are often taught separately. A robotics student could work with learners studying interface design, while computer science students could collaborate with those studying industrial engineering.
Such projects would help students understand that autonomous systems are not isolated technical products. They are part of larger operational environments involving people, processes, physical spaces and organisational responsibilities.
Ethical Responsibility in Human-Robot Workplaces
The increasing use of autonomous machines also raises important ethical questions. Robots may influence decisions involving worker safety, productivity, task allocation, workplace monitoring and access to employment opportunities. Students entering these environments should understand that technical performance is not the only measure of responsible automation.
They need to consider who is accountable when an autonomous system causes harm, how human oversight should be maintained and how automated monitoring affects worker privacy. They should also understand that the introduction of robots can change job responsibilities and may require employees to acquire new skills.
Ethical education should therefore be integrated into technical programmes rather than treated as a separate theoretical subject. Students could examine simulated workplace situations in which an automated system recommends an action that improves productivity but creates an unacceptable safety or fairness concern.
The purpose would be to develop the ability to question automated decisions and understand the responsibilities associated with deploying autonomous technologies.
Industry-Based Projects Can Close the Practical Skills Gap
Students often understand technical concepts better when they are required to apply them to realistic problems. Human-robot coordination is particularly suitable for project-based learning because it involves several connected challenges that cannot be solved through theory alone.
A project could involve designing a workflow in which a robot and a human worker perform different parts of an assembly process. Students would need to define the responsibilities of each participant, establish communication requirements, identify possible movement conflicts and determine how the system should respond to unexpected events.
Another project could involve planning the use of autonomous mobile robots in a warehouse. Students might examine route selection, object movement, human access, task scheduling and safety procedures. They could then use simulation to test whether their proposed workflow operates effectively.
These projects would create evidence of practical capability. Instead of demonstrating only that they completed a robotics course, students could show that they understand how to design and evaluate a collaborative working environment.
Internships and Real-World Exposure
Internships can provide an important transition between simulated learning and professional experience. Students may understand how autonomous systems work in a controlled educational environment, but workplace deployment introduces operational constraints that are difficult to reproduce completely in a classroom.
An internship in manufacturing, logistics, healthcare technology, robotics development or industrial automation can expose students to real workflows and professional expectations. They may observe how technicians monitor machines, how engineers respond to system faults and how employees coordinate their work with automated equipment.
However, internships should be connected to the student's previous learning. A student who has completed a course in robotics and a simulation project should ideally enter an internship with a clear understanding of the skills they want to develop. After the experience, they should be able to identify which competencies improved and which require further attention.
Within the EasyShiksha ecosystem, this could create a pathway connecting online learning, practical assessments, projects, internships and certificates. Each stage would contribute to a more complete understanding of human-robot collaboration and its professional applications.
Assessing Coordination Skills Instead of Testing Only Technical Knowledge
Conventional assessments often measure whether students can recall definitions, identify components or write correct code. These methods remain useful, but they cannot fully evaluate whether a learner can coordinate effectively with an autonomous machine.
A more comprehensive assessment approach would examine how students interpret robot behaviour, communicate instructions, allocate responsibilities, identify risks and respond to unexpected conditions. It could also assess whether students recognise the limitations of an automated system and know when human intervention is necessary.
For example, a simulated assessment might require a student to supervise an autonomous robot operating in a changing environment. The system could introduce an obstacle, modify a task priority or provide an uncertain sensor reading. The learner's response would reveal their ability to evaluate information and make appropriate decisions.
Such assessments could help distinguish between students who understand robotics concepts and those who can apply that understanding in collaborative environments.
How EasyShiksha Could Support Human-Robot Coordination Education
EasyShiksha's education ecosystem offers a useful conceptual foundation for exploring how students could develop the capabilities required for human-robot collaboration. Online courses could introduce the fundamentals of robotics, artificial intelligence, automation, sensors, control systems and human-machine interaction. Quizzes could evaluate conceptual understanding, while interactive simulations could allow learners to experiment with task allocation, movement coordination and machine behaviour.
Projects could provide opportunities to design collaborative workflows and solve practical problems involving autonomous systems. Internships could connect students with organisations working in robotics, manufacturing, logistics, healthcare technology and industrial automation. Certificates could document the learning stages completed, while career guidance could help students identify roles related to robotics engineering, automation, human-machine interaction and intelligent systems.
University programmes could provide deeper academic foundations in mechanical engineering, electronics, computer science, artificial intelligence and related disciplines. Games and challenge-based learning could introduce younger learners to the principles of coordination, sequencing and decision-making in accessible ways.
The most important opportunity lies in connecting these learning experiences. A student should not finish a robotics course without understanding how the knowledge could be applied in a collaborative workplace. Similarly, completing an internship should create an opportunity to identify additional technical or interpersonal skills that may be required.
This approach would position human-robot coordination as a continuous learning pathway rather than a single subject or isolated course.
Career Opportunities in Human-Robot Collaboration
As autonomous systems become more common across industries, professionals will be needed to develop, deploy, supervise, maintain and improve human-machine working environments. These opportunities extend beyond traditional robotics engineering.
Robotics engineers may design machines and control systems, while automation engineers may integrate robots into industrial processes. Human-robot interaction specialists may focus on how people communicate with and supervise autonomous systems. Safety engineers may evaluate operational risks, and systems engineers may coordinate the interaction between machines, software, infrastructure and people.
Other opportunities may emerge in warehouse automation, healthcare robotics, agricultural technology, autonomous inspection, industrial AI and service robotics. Many of these roles require interdisciplinary knowledge rather than expertise in a single technical area.
Students who develop both technical competence and coordination skills may therefore be better prepared to adapt to changing workplace requirements. Career guidance can help them understand the different roles available and identify suitable learning pathways.
Empower your team. Lead the industry
Get a subscription to a library of online courses and digital learning tools for your organization with
EasyShiksha
The future workplace may involve several autonomous systems operating alongside human teams. A factory could contain robotic arms, mobile transport robots and automated inspection systems. A logistics facility might use autonomous vehicles, sorting machines and AI-based inventory systems. A healthcare environment could combine robotic assistance, automated delivery and intelligent monitoring technologies.
As these systems become more interconnected, coordination will extend beyond one human working with one robot. People may supervise multiple machines, coordinate with automated teams and make decisions based on information generated by different autonomous systems.
This will increase the importance of systems thinking. Students must understand how one machine's action can affect another machine, how changes in task priorities influence an entire workflow and how human oversight should be organised across interconnected systems.
Educational programmes will need to prepare learners for these complex environments through interdisciplinary projects, simulation, practical experience and continuous skill development. The ability to work alongside autonomous machines may become an important professional capability across engineering and several non-engineering fields.
Conclusion: Preparing Students for a Workplace Shared With Machines
The expansion of autonomous machines is changing the meaning of technical competence. Knowing how to build, program or operate a robot remains important, but these abilities alone may not prepare students for workplaces where humans and machines must coordinate their actions. Future professionals will also need to understand shared autonomy, predict machine behaviour, communicate effectively, manage uncertainty, assess risks and recognise when human intervention is necessary.
The Human-Robot Coordination Gap highlights the distance between traditional robotics education and the practical capabilities required for collaborative workplaces. Closing this gap requires educational programmes to combine technical foundations with human factors engineering, simulation-based learning, interdisciplinary projects, safety awareness and real-world experience.
For EasyShiksha, this represents an opportunity to connect courses, quizzes, interactive learning, projects, internships, certificates, university programmes and career guidance into a structured pathway for developing human-robot collaboration skills. Students could progress from understanding autonomous systems to experimenting with simulated environments, designing collaborative workflows and gaining exposure to professional applications.
The future of robotics education should not focus exclusively on creating people who know how machines work. It should also prepare people to understand how humans and machines can work together responsibly, safely and effectively.
The next generation of technical professionals will not simply work with machines. They will work alongside autonomous systems, and education must prepare them for that shared future.
Anshika Jain is an Engineer, Developer, and Educational Content Author known for her dedication to technology and knowledge sharing. With a strong analytical mindset and a passion for innovation, she has consistently contributed to creating meaningful digital solutions and insightful educational articles.
Her ability to simplify complex technical concepts into engaging and easy-to-understand content makes her work valuable for students and learners across various platforms. Along with her technical expertise, Anshika is admired for her creativity, professionalism, and commitment to continuous learning.
She represents a perfect blend of technical excellence and impactful communication, inspiring others through both her development work and educational contributions.